Mastering Robust Control
A Mathematical Approach to Derivatives and Differentiation
Imagine having the power to analyze and control complex systems with confidence, even in the face of uncertainty.
284 pages13 chaptersMar 17, 2025Mathematics
About this book
"Mastering Robust Control" opens the door to this world, offering you a deep dive into the fascinating intersection of control theory and mathematical analysis. This book takes you on an enlightening exploration of robust control techniques, with a special focus on their applications in derivatives and differentiation. You'll discover how these powerful tools can be used to design systems that maintain stability and performance, even when faced with uncertainties or disturbances. From the foundations of control theory to advanced robust control methods, this comprehensive guide breaks down complex concepts into digestible chunks. You'll learn how to apply robust control principles to real-world problems, gaining invaluable skills that will set you apart in the fields of mathematics and engineering. Whether you're a student looking to expand your mathematical toolkit or a professional seeking to enhance your analytical capabilities, "Mastering Robust Control" provides the knowledge and insights you need to tackle challenging control problems with confidence and precision.
Table of contents
- IntroductionWhat is Robust Control?, The Importance of Derivatives in Control Theory, Overview of the Book, Mathematical PrerequisitesRead below
- Chapter 1: Foundations of Control TheoryClassical Control Theory, State-Space Representations, Transfer Functions and Frequency Domain, Stability Concepts
- Chapter 2: Derivatives and Differentiation in ControlBasic Concepts of Derivatives, Higher-Order Derivatives, Partial Derivatives and Gradients, Derivatives in Control Systems
- Chapter 3: Uncertainty and RobustnessTypes of Uncertainty in Control Systems, Measures of Robustness, Sensitivity Analysis, Modeling Uncertainty
- Chapter 4: H-infinity ControlThe H-infinity Norm, H-infinity Optimization Problem, H-infinity Controller Design, Examples of H-infinity Control
- Chapter 5: Lyapunov Stability TheoryLyapunov Functions, Stability Theorems, Lyapunov Equations, Robust Stability Analysis
- Chapter 6: Robust Optimization TechniquesConvex Optimization Basics, Linear Matrix Inequalities (LMIs), Semidefinite Programming, Robust Control Synthesis
- Chapter 7: Frequency Domain AnalysisBode Plots, Nyquist Stability Criterion, Gain and Phase Margins, Loop Shaping
- Chapter 8: Model Predictive ControlBasics of Model Predictive Control, MPC Problem Formulation, Robust Model Predictive Control, Applications of MPC
- Chapter 9: Adaptive Control MethodsIntroduction to Adaptive Control, Parameter Estimation Techniques, Model Reference Adaptive Control, Self-Tuning Regulators
- Chapter 10: The Small Gain TheoremBasics of the Small Gain Theorem, Analysis of Interconnected Systems, Robust Stability via Small Gain, Applications of the Small Gain Theorem
- Chapter 11: Robust Observers and EstimatorsObserver Design Principles, The Kalman Filter, H-infinity Observers, Robust State Estimation
- Chapter 12: Applications of Robust ControlAerospace Systems, Robotics and Automation, Process Control, Power Systems
- Chapter 13: Advanced Topics in Robust ControlRobust Nonlinear Control, Robust Control of Hybrid Systems, Distributed Robust Control, Learning-Based Robust Control
- ConclusionFuture Directions in Robust Control, Challenges and Opportunities
- AppendixMathematical Notation and Symbols, Numerical Methods for Robust Control
- Glossary
- Further Reading
Introduction
Welcome to the fascinating world of robust control theory and its applications in mathematical analysis, particularly in the realm of derivatives and differentiation. This introduction serves as your gateway to understanding the powerful tools and techniques that enable engineers and mathematicians to design systems that maintain stability and performance, even in the face of uncertainties and disturbances. As you embark on this journey, you'll discover how robust control theory provides a framework for tackling complex control problems with confidence and precision.
In the following sections, we'll explore the fundamental concepts of robust control, delve into the critical role of derivatives in control theory, provide an overview of the book's contents, and outline the mathematical prerequisites that will serve as a foundation for your learning. By the end of this introduction, you'll have a clear understanding of the road ahead and be well-equipped to dive deeper into the intricacies of robust control theory.
What is Robust Control?
Robust control is a branch of control theory that focuses on the design of control systems that can maintain stability and performance in the presence of uncertainties, disturbances, and modeling errors. In essence, robust control aims to create controllers that work effectively not just for a single, idealized model of a system, but for a range of possible system variations. This approach is crucial in real-world applications where perfect knowledge of a system's behavior is often unattainable.
The concept of robustness in control systems can be traced back to the early days of feedback control, but it gained significant traction in the 1970s and 1980s with the development of H-infinity control theory. This mathematical framework provided a rigorous way to quantify and optimize the robustness of control systems. Since then, robust control has evolved into a rich field with diverse techniques and applications across various domains of engineering and science.
At its core, robust control addresses several key challenges in system design:
- Parameter Uncertainty: Real systems often have parameters that are not known exactly or may vary over time. Robust control techniques aim to design controllers that work well across a range of possible parameter values.
- Unmodeled Dynamics: No mathematical model can capture all aspects of a real system. Robust control accounts for the presence of unmodeled dynamics that might affect system behavior.
- External Disturbances: Systems are often subject to external disturbances or noise. Robust controllers are designed to maintain performance even in the presence of these unpredictable inputs.
- Measurement Noise: Sensors used to measure system outputs are not perfect and introduce noise. Robust control techniques consider this uncertainty in measurements when designing feedback systems.
One of the fundamental concepts in robust control is the notion of stability margins. These margins quantify how much uncertainty a closed-loop system can tolerate before becoming unstable. Common stability margins include gain margin and phase margin, which measure the system's robustness to changes in loop gain and phase, respectively. These concepts build upon classical control theory but extend them to provide more comprehensive guarantees of stability and performance.
Another key aspect of robust control is the use of norm-based performance measures. The H-infinity norm, in particular, plays a central role in robust control theory. This norm measures the worst-case gain of a system over all frequencies and provides a way to quantify the system's sensitivity to disturbances and modeling errors. By minimizing the H-infinity norm, controllers can be designed to provide optimal performance in the worst-case scenario, ensuring robustness across a wide range of operating conditions.
Robust control theory also introduces powerful tools for analyzing and synthesizing control systems. Linear Matrix Inequalities (LMIs), for instance, provide a flexible framework for formulating and solving many robust control problems. These mathematical constructs allow designers to express complex stability and performance requirements in a form that can be efficiently solved using convex optimization techniques.
The applications of robust control are vast and diverse. In aerospace engineering, robust controllers ensure that aircraft and spacecraft can maintain stability and track desired trajectories despite variations in atmospheric conditions or vehicle parameters. In process control, robust techniques are used to design controllers that can handle the complexities and uncertainties inherent in chemical and manufacturing processes. Robotics, automotive systems, and power systems are other areas where robust control has made significant impacts, enabling the design of more reliable and high-performance systems.
As you progress through this book, you'll gain a deeper understanding of these concepts and learn how to apply them to real-world control problems. You'll see how robust control theory provides a powerful set of tools for designing systems that can withstand uncertainties and disturbances, ultimately leading to more reliable and effective control solutions across a wide range of applications.
The Importance of Derivatives in Control Theory
Derivatives play a fundamental role in control theory, serving as a cornerstone for understanding and designing dynamic systems. The concept of differentiation is intrinsically linked to the behavior of systems over time, making it an indispensable tool in the analysis and synthesis of control systems. In this section, we'll explore the multifaceted importance of derivatives in control theory, highlighting their applications and significance in various aspects of system modeling, analysis, and controller design.
At the most basic level, derivatives are essential for describing the dynamics of physical systems. The state-space representation, a fundamental concept in modern control theory, relies heavily on derivatives to express the rate of change of system states. For a continuous-time system, the state equations are typically written as a set of first-order differential equations:
where x represents the state vector, u is the input vector, and t is time. This formulation directly incorporates derivatives to describe how the system evolves over time, providing a powerful framework for analyzing and controlling complex systems.dx/dt = f(x, u, t)
In the context of feedback control, derivatives play a crucial role in shaping the system's response. The widely used PID (Proportional-Integral-Derivative) controller, for instance, explicitly incorporates the derivative of the error signal to improve system performance. The derivative term in a PID controller helps to anticipate future errors by considering the rate of change of the error, allowing for more responsive and stable control. This predictive capability is particularly useful in systems where rapid changes need to be addressed quickly, such as in motion control applications.
Derivatives are also fundamental in stability analysis, one of the primary concerns in control theory. The concept of Lyapunov stability, which is central to many robust control techniques, often involves the use of derivatives. Lyapunov functions, used to prove the stability of nonlinear systems, typically require the analysis of their derivatives along system trajectories. If the derivative of a Lyapunov function is negative definite, it indicates that the system's energy is decreasing over time, suggesting stability. This powerful approach allows for the analysis of complex nonlinear systems without the need for explicit solutions to the differential equations governing the system.
In frequency domain analysis, another cornerstone of control theory, derivatives manifest in the form of complex frequencies. The Laplace transform, a key tool in control engineering, converts time-domain differential equations into algebraic equations in the complex frequency domain. This transformation simplifies the analysis of linear time-invariant systems and allows for the easy computation of system responses to various inputs. The concept of transfer functions, which are ratios of output to input in the Laplace domain, inherently incorporates derivatives through the complex variable s, which represents differentiation in the time domain.
The importance of derivatives extends to advanced topics in robust control as well. In H-infinity control, for example, the optimization problem often involves minimizing the H-infinity norm of certain transfer functions. These transfer functions, being representations of the system in the frequency domain, implicitly involve derivatives. The sensitivity function and complementary sensitivity function, key concepts in robust control, are essentially transfer functions that capture how the system responds to disturbances and how well it tracks references, respectively. Both of these functions involve derivatives in their formulation and analysis.
In the realm of optimal control, derivatives play a central role in formulating and solving optimization problems. The calculus of variations, which underpins many optimal control techniques, relies heavily on the concept of functional derivatives. These generalized derivatives allow for the optimization of functionals, which are mappings from functions to real numbers. This mathematical framework enables the design of controllers that minimize certain cost functions over time, leading to optimal system performance.
Derivatives are also crucial in the implementation of adaptive control strategies. Many adaptive control algorithms use gradient-based methods to update controller parameters in real-time. These gradients are essentially derivatives of performance measures with respect to controller parameters, guiding the adaptation process towards improved performance. The ability to compute and utilize these derivatives efficiently is key to the success of many adaptive control schemes.
Furthermore, in the analysis of nonlinear systems, derivatives are essential for linearization techniques. The process of linearizing a nonlinear system around an operating point involves computing the Jacobian matrix, which consists of partial derivatives of the system equations with respect to state and input variables. This linearization allows for the application of linear control techniques to nonlinear systems, at least in the vicinity of the operating point, greatly expanding the toolbox available to control engineers.
As you progress through this book, you'll encounter numerous instances where derivatives and differentiation play pivotal roles in the development and application of robust control theory. From the basic modeling of dynamic systems to advanced techniques in optimal and adaptive control, a solid understanding of derivatives will be essential. By mastering these concepts, you'll be well-equipped to analyze complex systems, design effective controllers, and tackle the challenges of uncertainty and disturbances that are at the heart of robust control theory.
Overview of the Book
"Mastering Robust Control: A Mathematical Approach to Derivatives and Differentiation" is designed to provide you with a comprehensive understanding of robust control theory, with a particular focus on its mathematical foundations and applications in the realm of derivatives and differentiation. This book is structured to guide you through the fundamental concepts, advanced techniques, and practical applications of robust control, building your knowledge and skills progressively.
The book is organized into thirteen chapters, each focusing on a specific aspect of robust control theory. Here's a brief overview of what you can expect in each chapter:
- Foundations of Control Theory: This chapter lays the groundwork for the rest of the book, introducing you to classical control theory, state-space representations, transfer functions, and fundamental stability concepts. These basics will serve as a solid foundation for the more advanced topics to come.
- Derivatives and Differentiation in Control: Here, we delve deeper into the role of derivatives in control systems. You'll explore basic concepts of derivatives, higher-order derivatives, partial derivatives, and their applications in control theory.
- Uncertainty and Robustness: This chapter introduces the concept of uncertainty in control systems and explores various measures of robustness. You'll learn about sensitivity analysis and techniques for modeling uncertainty, which are crucial for designing robust controllers.
- H-infinity Control: A cornerstone of modern robust control theory, this chapter covers the H-infinity norm, optimization problems, controller design techniques, and practical examples of H-infinity control.
- Lyapunov Stability Theory: You'll explore Lyapunov functions, stability theorems, Lyapunov equations, and their applications in robust stability analysis. This chapter provides powerful tools for analyzing the stability of nonlinear systems.
- Robust Optimization Techniques: This chapter introduces you to convex optimization, Linear Matrix Inequalities (LMIs), semidefinite programming, and their applications in robust control synthesis.
- Frequency Domain Analysis: Here, you'll learn about Bode plots, the Nyquist stability criterion, gain and phase margins, and loop shaping techniques. These tools are essential for analyzing and designing control systems in the frequency domain.
- Model Predictive Control: This chapter covers the basics of Model Predictive Control (MPC), problem formulation, robust MPC techniques, and practical applications of MPC in various fields.
- Adaptive Control Methods: You'll explore adaptive control techniques, including parameter estimation, Model Reference Adaptive Control (MRAC), and self-tuning regulators. These methods allow control systems to adapt to changing conditions.
- The Small Gain Theorem: This chapter introduces the Small Gain Theorem and its applications in analyzing interconnected systems and ensuring robust stability.
- Robust Observers and Estimators: Here, you'll learn about observer design principles, the Kalman filter, H-infinity observers, and robust state estimation techniques.
- Applications of Robust Control: This chapter showcases real-world applications of robust control in aerospace systems, robotics and automation, process control, and power systems.
- Advanced Topics in Robust Control: The final chapter explores cutting-edge areas such as robust nonlinear control, control of hybrid systems, distributed robust control, and learning-based robust control techniques.
Throughout the book, you'll find a balance of theoretical concepts and practical applications. Each chapter includes detailed explanations, mathematical derivations, and examples to illustrate key points. You'll also encounter exercises and problems that will help you reinforce your understanding and develop your problem-solving skills in robust control.
The book concludes with a look at future directions in robust control research and the challenges and opportunities that lie ahead in this field. Additionally, appendices provide supplementary material on mathematical notation, symbols, and numerical methods for robust control, serving as valuable references as you work through the book.
By the end of this book, you'll have gained a deep understanding of robust control theory and its applications. You'll be equipped with the knowledge and skills to analyze complex control problems, design robust controllers, and apply these techniques to real-world systems. Whether you're a student looking to expand your mathematical toolkit or a professional seeking to enhance your analytical capabilities, "Mastering Robust Control" will provide you with the insights and tools you need to excel in this challenging and rewarding field.
Mathematical Prerequisites
To fully engage with the concepts presented in "Mastering Robust Control," it's important to have a solid foundation in certain mathematical areas. While the book aims to be as self-contained as possible, familiarity with the following topics will greatly enhance your understanding and ability to work through the material effectively. This section outlines the key mathematical prerequisites and provides a brief overview of each, helping you assess your readiness and identify areas where you might need to brush up your skills.
1. Calculus: A strong grasp of differential and integral calculus is essential. You should be comfortable with:
- Limits and continuity
- Differentiation of single and multivariable functions
- Integration techniques, including definite and indefinite integrals
- Partial derivatives and gradients
- Vector calculus, including divergence and curl
2. Linear Algebra: Many robust control techniques rely heavily on linear algebra. Key areas include:
- Matrix operations (addition, multiplication, inversion)
- Determinants and eigenvalues/eigenvectors
- Vector spaces and linear transformations
- Singular value decomposition (SVD)
- Positive definite and semidefinite matrices
3. Differential Equations: A solid understanding of ordinary differential equations (ODEs) is crucial. You should be familiar with:
- First-order and higher-order linear ODEs
- Systems of linear ODEs
- Basic concepts of nonlinear ODEs
- Stability analysis of equilibrium points
4. Complex Analysis: While not as extensively used as the previous topics, some familiarity with complex analysis is beneficial, particularly for frequency domain analysis. Key concepts include:
- Complex numbers and arithmetic
- Polar and exponential forms of complex numbers
- Basic complex functions and their properties
- Contour integration (at a basic level)
5. Probability and Statistics: Some aspects of robust control, particularly in dealing with uncertainties and stochastic systems, require a basic understanding of:
- Probability distributions
- Expected value and variance
- Basic statistical inference
- Random processes (at an introductory level)
6. Optimization Theory: While the book will cover optimization techniques specific to robust control, a basic understanding of the following will be helpful:
- Convex optimization
- Lagrange multipliers
- Gradient-based optimization methods
- Constrained and unconstrained optimization
7. Basic Control Theory: While the book will cover fundamental control concepts, prior exposure to the following topics will be beneficial:
- Feedback control systems
- Transfer functions
- Stability concepts (e.g., Routh-Hurwitz criterion)
- PID control
- Root locus method
If you find that you need to strengthen your knowledge in any of these areas, there are many excellent resources available, including textbooks, online courses, and video tutorials. Reviewing these topics before diving into the main content of the book will ensure that you're well-prepared to tackle the challenges and insights that robust control theory has to offer.
Remember, while a strong mathematical foundation is important, the book is designed to guide you through the material step by step. Key concepts will be explained in detail, and examples will be provided to illustrate how the mathematics applies to real-world control problems. As you progress through the book, you'll find that your mathematical skills will be reinforced and expanded, enabling you to tackle increasingly complex problems in robust control theory.
This is the end of the free sample. The full book has 13 chapters.
Want this book written for you?
Tell us your goals and background, and get your own version of this book, tailored by AI to you.


Benefits of AI-tailored books
- Read one book, not ten:
- all the Mathematics knowledge you need, gathered into a single book.
- Save days of learning:
- tell us your goals, choose your topics, and the whole book is built around them.
- Learn effortlessly:
- Mathematics book written for your specific background and expertise.
- Understand at a glance:
- includes charts, tables, timelines, checklists, decision trees, and more.
- Stay current:
- written the day you order it, not years ago.
- Trust what you read:
- every book is checked for accuracy, with real research when your subject needs it.
Create your unique book in 3 steps
- 1. Select your focus
Select the focus of your Mathematics book and share your background
- 2. Personalize your book
Specify your goals and choose sub-topics to include
- 3. Get your tailored book
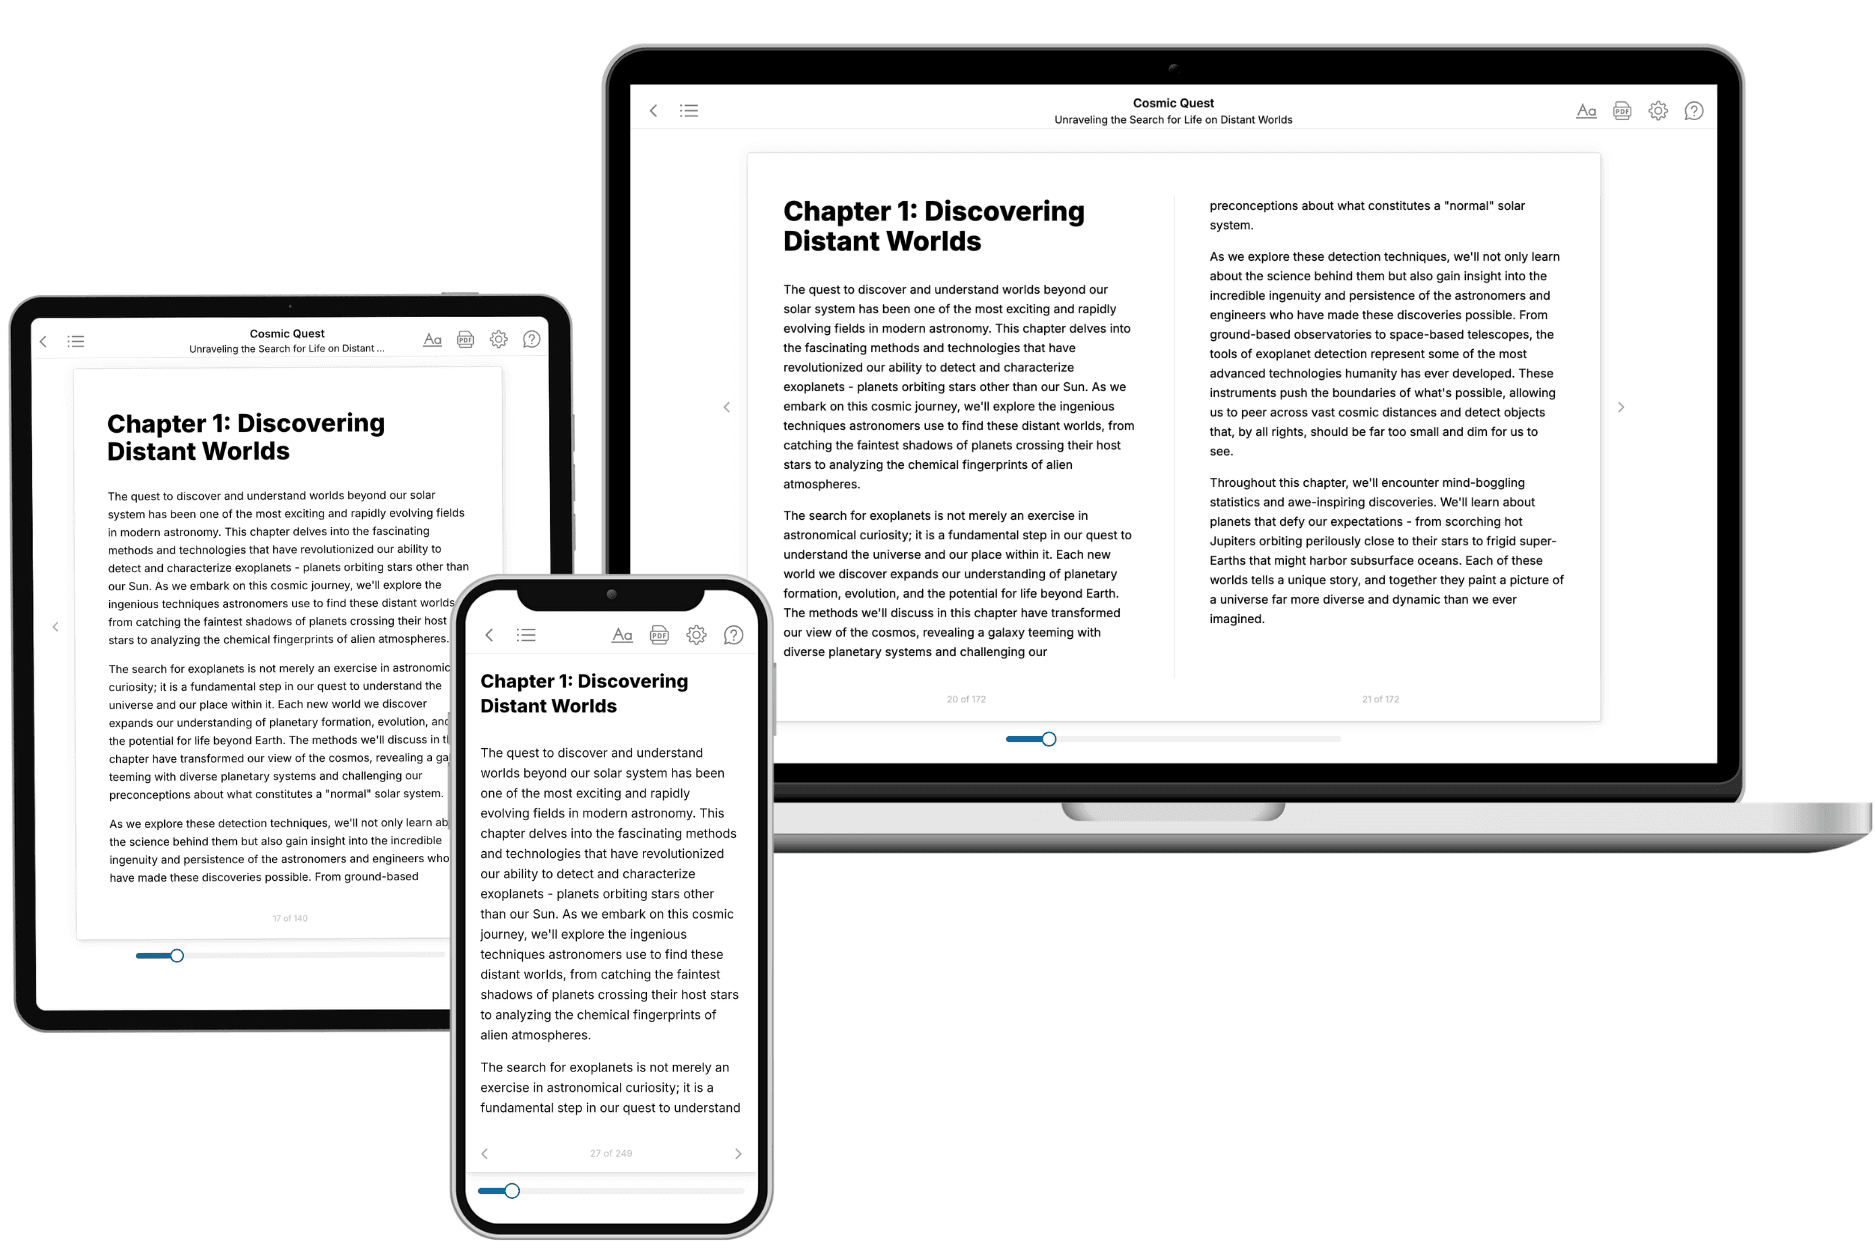
Your book is ready in 10 minutes. Read it online, download as EPUB or PDF, or send to Kindle.
Frequently asked questions
- What is TailoredRead?
TailoredRead creates complete, full-length nonfiction ebooks, written specifically for you. Tell us what you want to learn and why, and TailoredRead writes you a complete ebook on it, with charts, tables, and diagrams throughout. Read it online, on Kindle, or on any e-reader, or download it as a PDF or EPUB. Every book is written fresh the day you order it.
- How is the book tailored to me?
Before anything is written, you answer a few short questions about your goals, your background, and the topics you care about. Your book is then planned around your answers: written at your level, focused on your goals, and covering the topics you chose, instead of the one-size-fits-all book a store sells everyone.
- Will it read like generic AI content?
No. Your book isn't a chat transcript: it's planned chapter by chapter before a single word is written, told in a clear book voice, and explains ideas visually with charts, tables, and diagrams. After writing, every book goes through an editorial pass that polishes chapters so the book reads consistent from start to finish. Judge for yourself: browse thousands of sample books on our Explore Books page.
- How accurate is the content?
Our AI first checks whether your subject needs live research. Niche and fast-moving subjects are researched before writing, and the book plan and chapters are grounded in what it finds. After writing, every book goes through a quality pass that checks its facts and consistency, and researched books list their sources in a Notes section at the back.
- How long is the book?
You choose the length: Comprehensive (250-300 pages), Detailed (150-200 pages), Essential (70-100 pages), or Short (30-50 pages).
- Does the book include visuals?
Yes. Every book includes charts, tables, and diagrams: timelines, checklists, step-by-step guides, decision trees, comparison tables, matrices, and bar charts. A typical book includes dozens of these visual elements.
- Can I read it on Kindle? What formats can I download?
Yes. Every book can be read in our online reader or downloaded as a PDF or EPUB. The EPUB can be opened with Kindle, Apple Books, Kobo, and any e-reader. The Commercial and Author licenses also include an editable Word (DOCX) and Markdown download.
- How much does it cost?
About the price of a regular ebook. The exact price depends on your book's length and complexity, from $2 for the shortest books to $35 for the most comprehensive, and it's shown when you review your book, before you commit to anything. Each book is a one-time purchase, yours to keep, no subscription. Licenses that let you share, teach, or publish your book range from $35.99 to $49.99.
- Can I preview the book before purchasing?
Before you pay, you'll see what your book will cover: the title, a detailed description, the estimated length, and the complete chapter-by-chapter table of contents, so you know what you're getting before you decide. The full text itself is written after you purchase.
- How long does it take to create a book?
About 10 minutes. You can start reading the opening chapters while the rest is still being written.